


Mobile Humanoid
We develop mobile humanoid robots capable of stable bimanual operations and high-degree-of-freedom tasks,
based on differentiated capabilities in mobility, RCS, and multi-hand technologies.
based on differentiated capabilities in mobility, RCS, and multi-hand technologies.
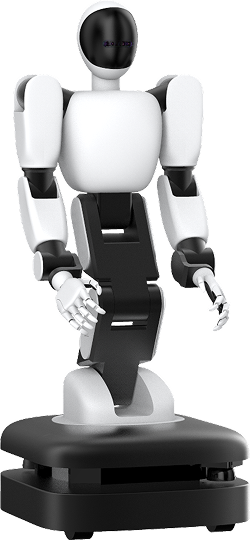
The system demonstrates exceptional flexibility and performance even in complex and unstructured work environments.
Based on advanced SLAM-based autonomous navigation and AI-driven integrated technologies of AMMR, mobile humanoids are developed in-house.
By combining AMMR-based precise driving and docking technologies with 16-axis hand control,
the system enables stable execution of complex bimanual motions and high-degree-of-freedom tasks.
Specification
| Robot Type | Mobile Humanoid (Dual-arm) |
|---|---|
| Key Features | Mecanum wheels, 5-finger hands, CE certified (industrial), RCS, Physical AI |
| Dimensions | 600mm x 640mm x 1,650mm (Arm span : 1,280) |
| Arm Payload | TBD |
| DoF | Arms (7 DoF each), Hands (21 DoF each), Waist (3 DoF), Head (2 DoF) : Total: 61 DoF |
| Hand Payload | 3kg |
| Travel Speed | TBD |
| Mobility | Mecanum wheel–based omnidirectional high-speed movement |
| Battery / Power | 50V 50Ah (2,500Wh) |
| SW / Platform | ROS2, Python, C++, AI(Perception / Reinforcement Learning), Jetson AGX Orin |
| Robotic Hand | Allegro Hand (5-finger) |
※ DoF: Degree of Freedom